 Tel:
 Email:
 WhatsApp:
Description
Key Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | ADEPT TECHNOLOGY (now Omron Adept) |
| Part Number | 12000-310 |
| Product Name | SmartMI6 Controller Module |
| Common Revision | Rev.V |
| Input Voltage | 24V DC |
| Input Current | 5A |
| Communication | Ethernet port, RS232/RS485 serial |
| Programming Environment | V+ language |
| Compatible Robots | Adept Cobra, Viper, Python series |
| Operating Temperature | -10 °C to +60 °C (verify with OEM manual) |
| Status | Legacy / discontinued-series spare |
Product Introduction
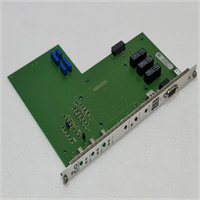
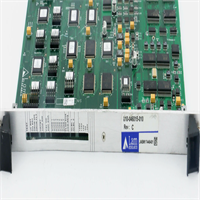
If you have ever stood in front of a dead Adept Cobra on a packaging line with production screaming down your neck, you know the SmartMI6 is not “just another controller.” The ADEPT TECHNOLOGY 12000-310, commonly marked as SmartMI6 Rev.V, is the brain behind many Adept SCARA robots — handling motion execution, I/O handling, and V+ program interpretation in one compact module.Engineers keep this module in the spares bin because it is a known quantity in Adept installations. It runs V+ natively, talks Ethernet and serial, and interfaces directly with Adept servo amplifiers and teach pendants. At 24V DC / 5A, it is not a power-hungry beast, but it is sensitive to dirty power and bad grounding. I have seen these modules survive a decade in clean rooms and fail within months in dusty assembly cells where someone ignored the ground stud. The revision matters — Rev.V is common, but earlier or later builds may differ in firmware or connector pinout.
Quality SOP & Tech Pitfalls
The Lab Report (SOP)
- Visual and counterfeit check: Verify ADEPT TECHNOLOGY label, 12000-310 marking, revision code (e.g., Rev.V), and serial number.
- Connector inspection: Check Ethernet port, serial connectors, and robot interface connectors for bent pins or corrosion.
- Continuity check: Use a Fluke 115 or equivalent to verify power input and communication pin continuity.
- Live test: Apply 24V DC and verify boot sequence, LED indicators, and Ethernet link.
- Communication validation: Confirm V+ terminal access via Ethernet or serial; verify robot handshake signals.
- Firmware logging: Record firmware version for compatibility with the installed robot and teach pendant.
- ESD sealing: Anti-static bag, desiccant, rigid box, and photo documentation.
The Engineer’s Warning (Pitfalls)
- Revision mismatch. Rev.V may not be pin-compatible with earlier SmartMI6 builds. I have seen a crew swap a “close enough” controller and spend a full shift chasing a phantom teach pendant communication error that traced back to a different firmware revision.
- Grounding is non-negotiable. The SmartMI6 is picky about ground loops. A floating ground on the robot arm or controller chassis can cause intermittent faults that look like hardware failure but are really EMI.
- Battery-backed memory. If the module has a backup battery for program retention, a dead battery means lost calibration and programs. Check it before the line goes down, not after.
Installation & Configuration Guide
1. Pre-Installation ⚠️
- Follow site LOTO procedures.
- Disconnect 24V DC power and wait for capacitors to discharge.
- Photograph all connectors, cable labels, robot model tag, and the controller revision label.
2. Removal
- Label every cable by connector name (Ethernet, serial, robot interface, power).
- Disconnect cables carefully; do not pull by the wires.
- Release mounting hardware and remove the module.
3. Installation
- Verify the replacement revision matches the original. Rev.V is common, but confirm against the old module.
- Seat all connectors fully; verify Ethernet and serial pins are not bent.
- Reinstall mounting hardware and ensure proper grounding to the chassis.
4. Power-On & Testing
- Restore 24V DC power.
- Verify LED boot sequence and Ethernet link status.
- Connect teach pendant and verify V+ terminal access.
- Run a low-speed jog test on each axis; verify no following errors.
- Confirm I/O mapping matches the original configuration.
- Document the revision, firmware version, and test results.
Compatible Replacement Models
- ✅ 12000-310 Rev.V → 12000-310 Rev.V: Drop-in replacement if the revision, firmware, and connector layout match.
- ⚠️ 12000-310 Rev.V → 12000-310 other revision: May require firmware update or V+ program adjustment; verify connector pinout and robot compatibility before energizing.
- ❌ 12000-310 → Non-Adept controller: Hardware modification required. Do not attempt unless redesigning the entire robot cell and accepting full integration risk.
Frequently Asked Questions (FAQ)
Can I hot-swap this controller?
No. The SmartMI6 is not designed for hot swapping. Power down the robot controller and follow LOTO procedures. Swapping live can damage the module and the robot servo amplifiers.Is Rev.V the only revision?
No. Public listings show Rev.V as common, but other revisions exist. Always verify the revision on the label before purchasing.What robots does this support?
It is commonly used with Adept Cobra SCARA and Viper articulated robots. Confirm compatibility with your specific robot model and V+ software version.What fails first on these modules?
Ethernet ports, backup batteries, and power input capacitors. The Ethernet connector takes a beating in production environments, and a dead backup battery can wipe your calibration data.Is Adept Technology still in business?
Adept Technology was acquired by Omron Adept. Legacy parts like the 12000-310 are available through surplus channels, but OEM support may be limited. Verify supplier reputation before purchasing.Does it come with V+ software?
No. The module runs V+ firmware, but the programming software and licenses are separate. Ensure you have access to the V+ development environment before commissioning.