 Tel:
 Email:
 WhatsApp:
Description
Key Technical Specifications
| Parameter | Detail |
|---|---|
| Manufacturer | Bosch Rexroth (Indramat) |
| Model | MSK040C-0450-NN-M1-UG1-NNNN |
| Series | IndraDyn S MSK |
| Motor Size | 040 (approx. 82 mm × 124.5 mm frame) |
| Motor Length | C (approx. 185.5 mm) |
| Winding / Speed Code | 0450 → rated speed 4500 rpm |
| Cooling | NN = natural convection |
| Encoder | M1 = multiturn absolute, Hiperface interface, 128 signal periods, 4096 turns |
| Holding Brake | 1 = electrically released holding brake present |
| Brake Torque | Verify on nameplate; similar MSK040C brake variants are commonly 4 Nm |
| Shaft / Seal | UG1 = plain shaft with shaft seal ring (no keyway) |
| Protection | IP65 |
| Connector | Rotatable power/encoder connector, typically 240° |
| Compatible Drives | Bosch Rexroth IndraDrive systems |
| Origin | Germany |
Product Introduction
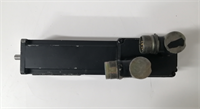
The MSK040C-0450-NN-M1-UG1-NNNN is a Bosch Rexroth IndraDyn S synchronous servomotor built for compact motion axes that need absolute position feedback and fail-safe holding. The “0450” winding code indicates a 4500 rpm rated speed, which makes it suitable for fast indexing, packaging, pick-and-place, and small robotic or machine-tool axes.The M1 encoder provides multiturn absolute position through a Hiperface interface, so the drive can recover axis position after power-down without a homing cycle. The “1” brake option adds an electrically released holding brake, which is intended to hold the axis at standstill — not as a service brake or safety brake. The UG1 shaft option means a plain shaft with seal ring, which is important when replacing a keyed-shaft variant.
Quality SOP & Tech Pitfalls
The Lab Report (SOP)
- Nameplate verification: confirm full type code MSK040C-0450-NN-M1-UG1-NNNN, serial number, and MNR/R-number.
- Mechanical inspection: check flange, shaft run-out, connector condition, seal ring, and mounting hardware.
- Insulation test: measure winding insulation resistance before energizing.
- Brake check: verify holding brake releases at the correct DC voltage and holds when de-energized.
- Encoder check: confirm multiturn absolute position is readable through the Hiperface interface.
- No-load run: verify rotation direction, noise, vibration, and bearing condition.
- Parameter match: confirm motor type code is entered correctly in the IndraDrive configuration.
- Packing: anti-static protection for encoder connector, shaft protection, and rigid export crate.
The Engineer’s Warning (Pitfalls)
Do not substitute this motor with an MSK040C-0450-NN-S1-… or MSK040C-0450-NN-M1-UP1-… without checking the shaft, brake, and encoder. S1/M1 changes encoder type; UP1/UG1 changes shaft and seal configuration; a “0” brake code means no brake at all.The second common failure is mismatching the encoder interface. An EnDat encoder variant will not plug into a Hiperface encoder cable without verifying pinout and drive firmware support. Always match the full type code, not just “MSK040C-0450.”
Installation & Configuration Guide
1. Pre-Installation ⚠️
- Confirm whether the axis uses the holding brake for vertical loads or emergency stop retention.
- Photograph the nameplate, connector orientation, cable labels, and drive parameters.
- Verify the replacement type code matches exactly: MSK040C-0450-NN-M1-UG1-NNNN.
- Confirm the drive supports a multiturn Hiperface encoder and the correct brake output.
2. Removal
- Lock out power to the drive and motor.
- Wait for DC bus discharge.
- Support the mechanical load before releasing the brake.
- Disconnect power, brake, and encoder cables.
- Unbolt the motor and remove it from the coupling or gearbox.
3. Installation
- Inspect the coupling, gearbox input, and shaft seal before mounting.
- Install the replacement motor with correct flange alignment.
- Reconnect power, brake, and encoder cables with correct orientation.
- Verify the encoder connector is fully seated and the rotatable connector is positioned correctly.
4. Commissioning
- Enter the correct motor type code in the IndraDrive project.
- Verify encoder communication and multiturn position.
- Test brake release and hold function under controlled conditions.
- Perform motor identification/commutation if required by the drive.
- Run low-speed and full-speed tests before returning the axis to production.
Compatible Replacement Models
- ✅ MSK040C-0450-NN-M1-UG1-NNNN (same full type code): Direct replacement. Preferred option.
- ⚠️ MSK040C-0450-NN-M1-UG0-NNNN: Same motor and encoder, but without holding brake. Acceptable only if the application does not require a brake.
- ⚠️ MSK040C-0450-NN-M1-UP1-NNNN: Similar motor, but UP1 indicates a keyed shaft variant. Mechanical coupling must be verified.
- ❌ MSK040C-0450-NN-S1-… variants: Different encoder configuration; not a guaranteed drop-in replacement.
- ❌ MSK040C-0600-… variants: Different winding and speed rating; drive parameters and mechanical performance will differ.
Frequently Asked Questions (FAQ)
What does M1 mean in this type code?
M1 indicates a multiturn absolute encoder with Hiperface interface, typically 128 signal periods and 4096 turns.Does this motor have a brake?
Yes. The “1” in the brake position indicates an electrically released holding brake. It is for holding position at standstill, not for dynamic braking or personnel protection.Can I replace it with a UP1 version?
Only if the mechanical coupling accepts a keyed shaft. UG1 is a plain shaft with seal ring; UP1 is a keyed shaft with seal ring.What drive does it work with?
It is designed for Bosch Rexroth IndraDrive systems. The drive must support Hiperface multiturn absolute encoders and the correct brake output.Is this motor still produced by Rexroth?
Availability depends on current Rexroth product status. Many MSK040C variants are now sourced through surplus or verified used stock. Confirm the exact type code and test condition before purchase.What documentation should I keep?
Save the nameplate photo, full type code, serial number, encoder cable pinout, brake voltage, drive parameter set, and last maintenance record. On legacy Rexroth axes, the type code is the fastest way to avoid a wrong replacement.